Humax Mobility affiliate Kail23Jasper is launching a proof-of-concept project for vehicle exterior damage detection technology using artificial intelligence (AI). With the era of autonomous driving and robotaxis approaching, the company aims to automate vehicle condition checks and enhance the efficiency of large-scale fleet operations.
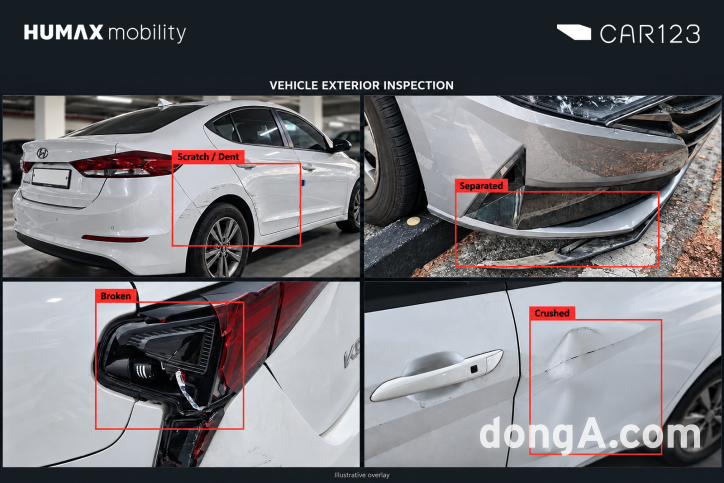
Kail23Jasper announced that it will conduct a proof-of-concept for a “vehicle exterior defect detection system (photo)” in cooperation with Professor Jangwoo Lee’s laboratory at Seoul National University and AI specialist Hodoo AI Lab. The system uses AI to analyze photos taken during the car-sharing vehicle pick-up and return process to determine whether there is exterior damage such as scratches or dents and to identify its location.
Currently, inspection of returned car-sharing vehicles is carried out by staff who manually review photos and records taken by users. As the number of operating vehicles increases, the volume of photos to be inspected and the associated workload also grow. In particular, for robotaxis that operate without drivers, an automated inspection system capable of quickly assessing vehicle condition before and after operation is regarded as a key operational infrastructure.
In this proof-of-concept, the companies will develop a system that analyzes photos and videos of vehicles taken from multiple angles using AI to prioritize identification of vehicles and areas suspected of damage. Inspectors will be able to focus on the areas highlighted by AI, which is expected to reduce inspection time and improve inspection efficiency.
The core technologies are threefold: “object detection,” which identifies suspected damage areas in images; “segmentation,” which distinguishes the shape and area of scratches or breakages at the pixel level; and “image registration,” which aligns the position and size of past and current images to compare changes in the vehicle exterior.
The proof-of-concept will proceed in two stages. In stage one, prototype development and data collection will be carried out in parallel, and detection and segmentation model training and inference systems will be established. In stage two, the system will be scaled up and model performance improved, while also examining the feasibility of using image registration to analyze changes in vehicle condition.
In a preliminary evaluation, the optimized model achieved an accuracy of approximately 85% in distinguishing normal from defective cases within a dataset of 100 normal images and 100 defective images. For this proof-of-concept, the company plans to build data aligned with actual inspection criteria and further advance the model to verify its applicability in real-world operations.
Song Yoon-hwa, CEO of Kail23Jasper, said, “We are combining AI technology with the know-how accumulated over the past 28 years in vehicle operation, maintenance, and management to preemptively secure automatic vehicle condition detection technology required for robotaxi fleet operations,” adding, “We will continue to develop the technology so that vehicle conditions can be managed reliably even in autonomous driving fleet environments.”
Kail23Jasper plans to explore ways to apply the technology to actual vehicle operation environments based on the proof-of-concept results. The company is also considering linking it with group-level projects, such as the “Robotaxi Fleet Operation Infrastructure Joint Business Council,” launched last month by the Humax Mobility Group.
The company intends to advance its vehicle condition management technology by leveraging its operational experience from maintaining and managing approximately 19,000 vehicles annually. Once AI-based exterior inspection is commercialized, it is expected to be used not only to enhance the management efficiency of large-scale car-sharing operations, but also to improve the management efficiency of autonomous driving and robotaxi fleets.
ⓒ dongA.com. All rights reserved. Reproduction, redistribution, or use for AI training prohibited.
Popular News